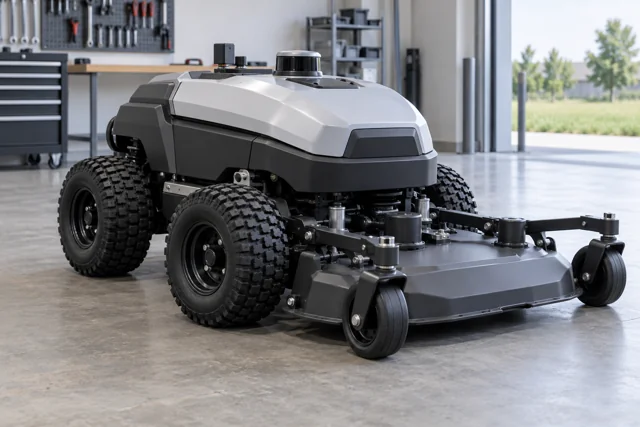
Commercial tracked mowers
Three cutting configurations with technical tables, base remote operation and optional precision-navigation/autonomous upgrades.
EQUIPMENT CONFIGURATIONS / FUNCTIONAL BREAKDOWN
Open a specific equipment task to inspect its physical arrangement and electrical functions. For industry categories, start with Applications.
COMPONENT ENQUIRIES
Differential traction, pack input and conversion, E-stop interfaces and service connectors.
Wheel-drive duty and auxiliary supply.
Open equipment & modules ↗
Separate travel and lift actuator demand.
Open equipment & modules ↗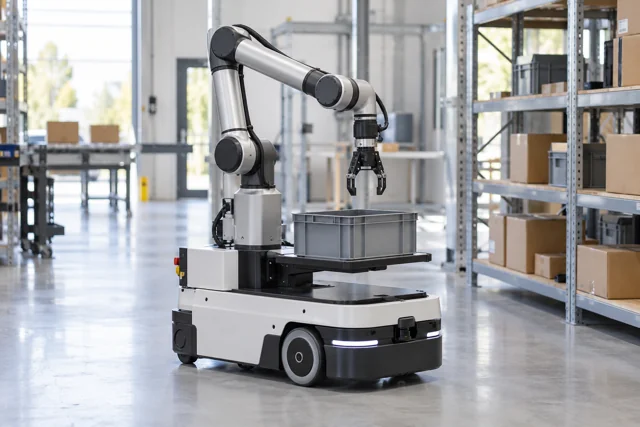
Mobile base and separately specified handling axis.
Open equipment & modules ↗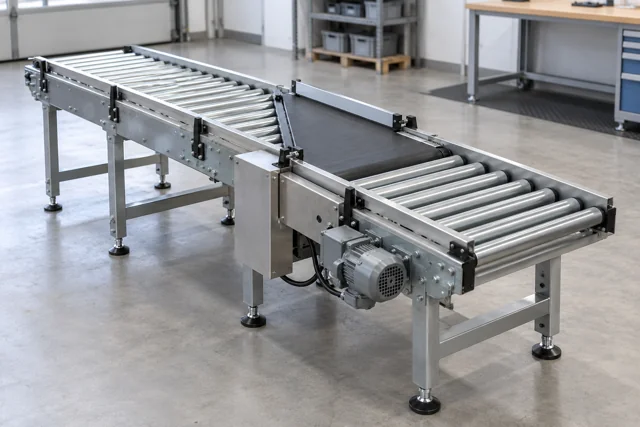
Transport drive, diversion axis and reference inputs.
Open equipment & modules ↗APPLICATION DIRECTION
Mobile-platform electrical interfaces adapted for slope, dust, washing and work attachments.
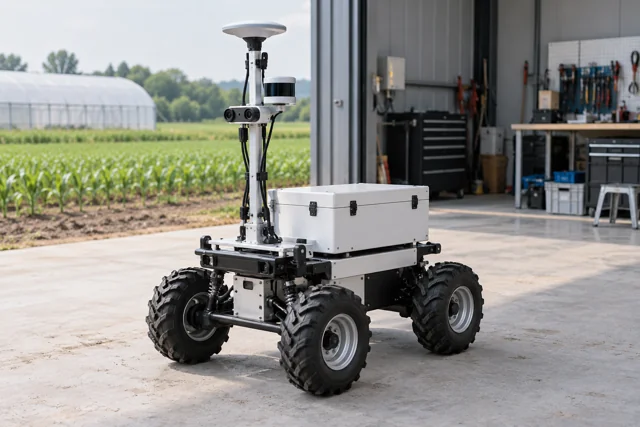
Instrument rails separated from traction.
Open equipment & modules ↗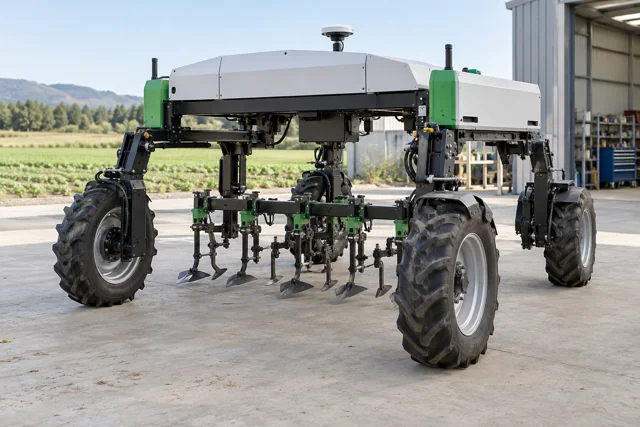
Traction and tool actuation as separate loads; mower cutting loads use the outdoor configuration.
Open equipment & modules ↗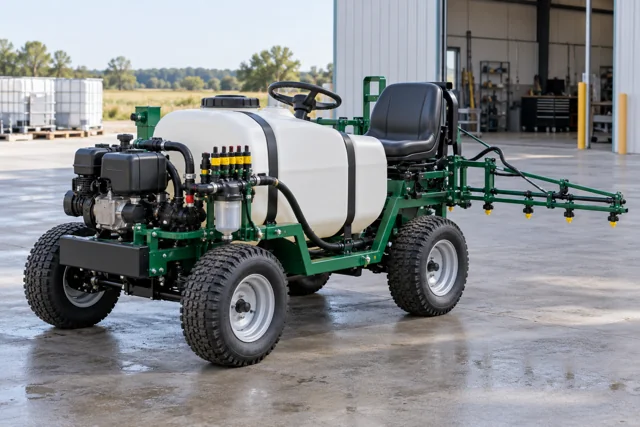
Pump supply, valve coils and connectors only.
Open equipment & modules ↗
State powered or towed arrangement before specifying drive components.
Open equipment & modules ↗COMPONENT ENQUIRIES
Separate traction and working loads; edge/limit inputs and service-exposed connectors.
APPLICATION DIRECTION
Inspection platforms and a positioning axis, with dust and moving-cable conditions.
COMPONENT ENQUIRIES
Matched motor/drive, transmission, reference and travel limits. AC-DC only for plugged-in equipment.
FUTURE APPLICATION DIRECTIONS
Separate from the six current project lines. These pages organize electrical interfaces for equipment developers; they are not finished medical-device offers.
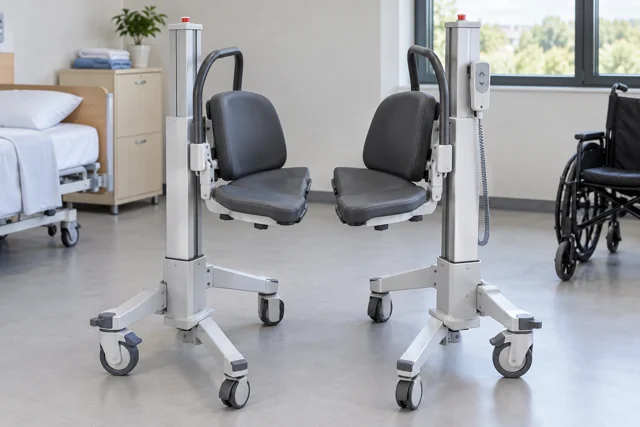
Split-seat transfer and supported-lift arrangements; device suitability remains with the equipment manufacturer and clinical assessment.
Open equipment & modules ↗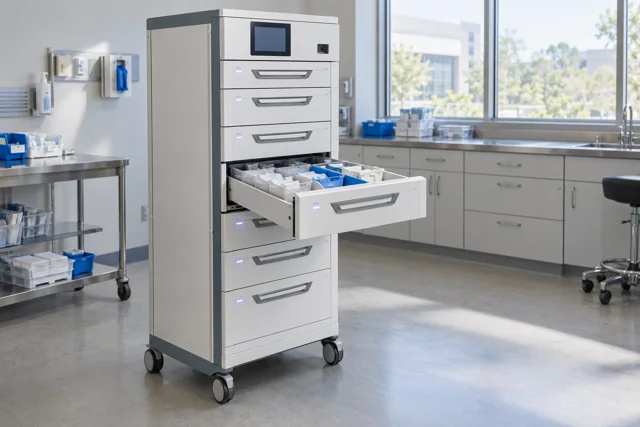
Clinical supply and home-access cabinetry: locks, position inputs, auxiliary power and connections.
Open equipment & modules ↗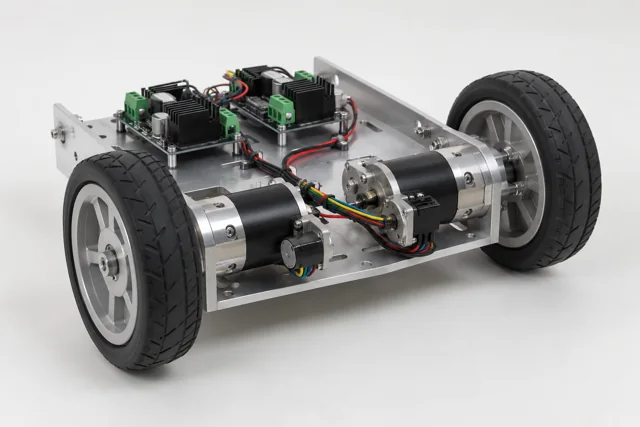
Wheel drive moves the platform. Separate wheel-drive demand from any payload or tool load.
Functions → sub-blocks → components ↗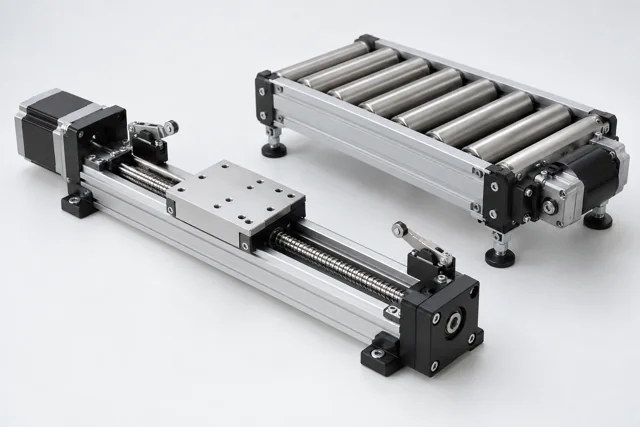
Lifting, picking and positioning have separate actuator interfaces. An articulated arm requires the arm supplier’s axis architecture; this is not a complete robot-arm offering.
Functions → sub-blocks → components ↗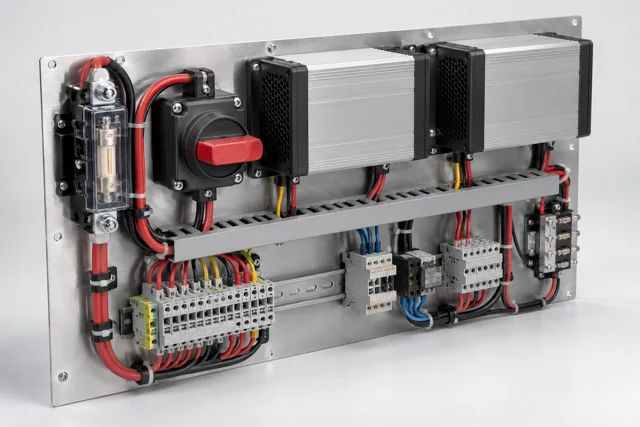
Pack input, drive branches and auxiliary rails are separate selection blocks. AC-DC is relevant only when the machine is plugged in.
Functions → sub-blocks → components ↗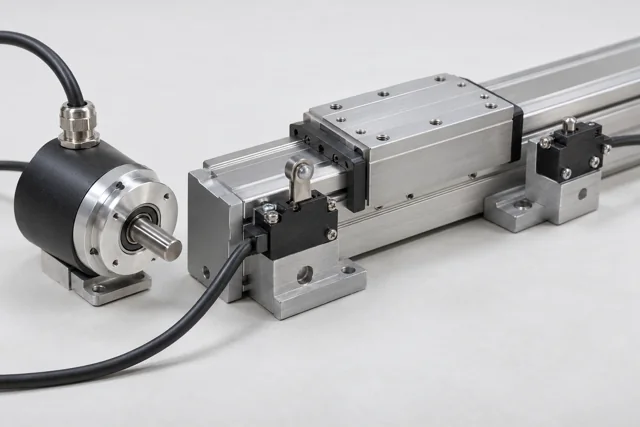
Encoder feedback, a home reference and a travel limit serve different functions. Match each device to the receiving controller.
Functions → sub-blocks → components ↗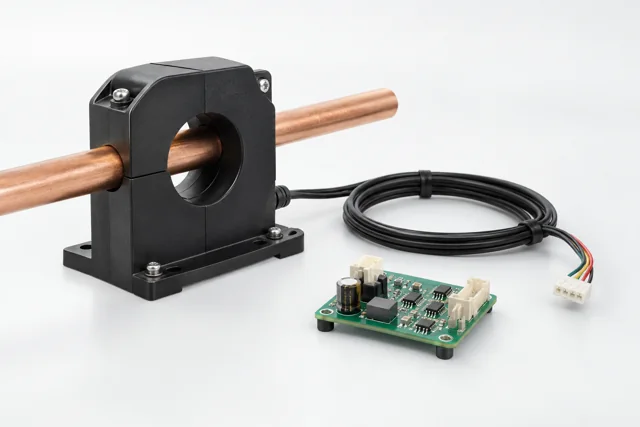
Current measurement observes a pack, branch or phase. The receiving controller implements the defined monitoring behavior; a measurement device alone is not a safety function.
Functions → sub-blocks → components ↗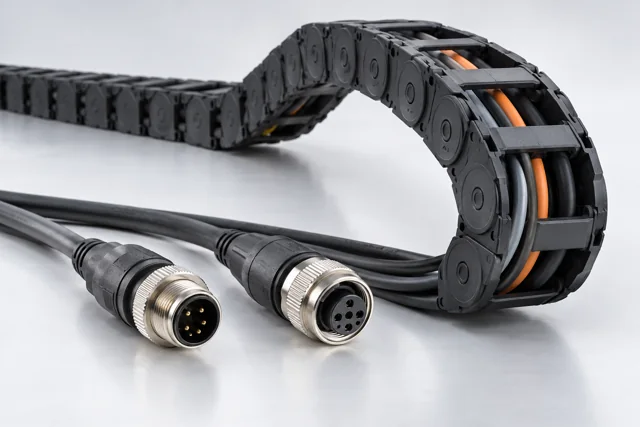
Power, signal and moving-cable installation must be defined as complete mating and routing arrangements.
Functions → sub-blocks → components ↗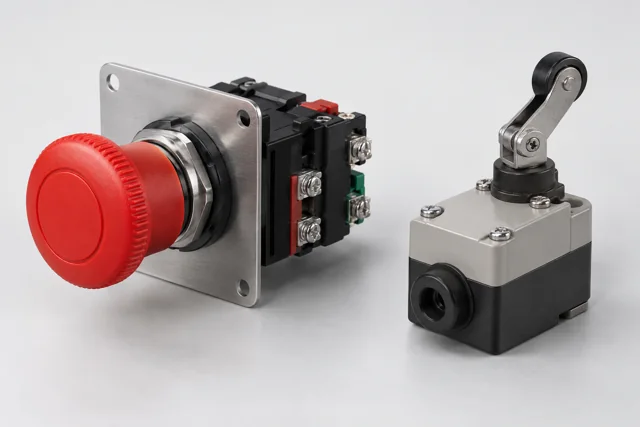
Separate machine stopping and restart requirements from ordinary position inputs. The equipment risk assessment defines the safety architecture.
Functions → sub-blocks → components ↗EQUIPMENT / PROJECT DEVELOPMENT
Three cutting configurations with technical tables, base remote operation and optional precision-navigation/autonomous upgrades.
BEV, range-extended and plug-in hybrid architectures for farms, sites and outdoor work.
VCU hardware resources, body electronics, gateways, diagnostics and driving-domain integration.
Onboard acquisition, monitoring, fleet operations, OTA, diagnostics and private deployment.
PROJECT / MODULE / COMPONENT